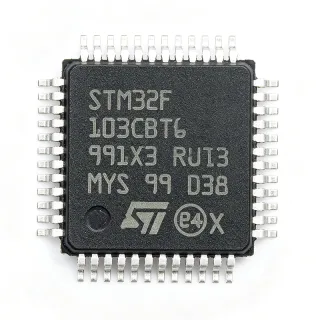
ATMEGA165A-AU - 8-Bit AVR MCU 16KB Flash 16MHz | Microchip
MPN: ATMEGA165A-AU ✓ Active| Qty | Unit Price | Extended |
|---|---|---|
| 1 | $5.42 | $5.42 |
| 10 | $4.88 | $48.80 |
| 100 | $4.34 | $434.00 |
| 500 | $3.91 | $1,955.00 |
| 1,000 | $3.47 | $3,470.00 |
ATMEGA165A-AU Overview
An 8-bit microcontroller (MCU) is a single-chip computer that integrates a CPU, program memory, data memory, and peripherals such as timers, serial interfaces, and analog-to-digital converters. Within the product hierarchy, the ATMEGA165A-AU is an AVR-family MCU, which is a member of the 8-bit microcontroller class, itself part of the broader embedded processor and semiconductor market. The AVR architecture uses a modified Harvard layout with 32 general-purpose working registers and 133 powerful instructions, most executing in a single clock cycle.
Key features include 16 KB of Flash with read-while-write capability, 512 B of byte-addressable EEPROM for non-volatile parameter storage, 1 KB of internal SRAM, a JTAG interface supporting boundary-scan and on-chip debug, and a 10-bit successive-approximation ADC. The device also integrates a programmable watchdog timer, brown-out detection, and multiple power-saving sleep modes that reduce current consumption for battery-powered designs.
The ATMEGA165A-AU is fabricated using Atmel's high-density non-volatile memory process, combining Flash program storage with EEPROM data storage on a single die. Its fully static operation allows the clock to be halted without losing state, and the wide 2.7 V to 5.5 V supply range permits direct operation from 3.3 V or 5 V rails without external regulation.
Typical applications include industrial control panels, battery management systems, portable instrumentation, home automation nodes, motor control, and legacy embedded designs migrating from older ATmega parts. The 64-pin TQFP footprint with 54 I/O lines suits designs requiring many digital interfaces plus analog sensing.
When designing with this device, decouple every VCC pin with a 100 nF ceramic capacitor placed close to the pin, and provide a 10 uF bulk capacitor near the package. The JTAG interface shares pins with Port F, so plan the debug connector and application I/O allocation together.
This page synthesizes distributor pricing, drop-in alternatives, and practical design notes not found in the manufacturer datasheet, giving engineers a single reference for selection, replacement, and layout decisions.
Drop-in alternatives for ATMEGA165A-AU — same package, pin-to-pin compatible. Different-package parts requiring PCB rework are excluded.
Variants in this series
Same-series models that are drop-in compatible with ATMEGA165A-AU (same form factor and footprint) — differing in Package, Instruction Set, Timers, Flash Memory, Operating Temperature.
Quick Comparison Tool — Select alternative parts for side-by-side comparison:
ATMEGA165PA-AU
✅ Drop-In✓ In Stock
$2.05 / Unit
View Datasheet →ATMEGA165A-AUR
✅ Drop-In✓ In Stock
Contact for price
View Datasheet →ATMEGA325A-AU
✅ Drop-In📋 Reference alternative (not in catalog)
ATMEGA645A-AU
✅ Drop-In📋 Reference alternative (not in catalog)
ATMEGA169A-AUR
✅ Drop-In📋 Reference alternative (not in catalog)
ATMEGA165A-AU Maximum Ratings & Electrical Characteristics
| Core Processor | AVR 8-bit RISC |
| Program Memory Size | 16 KB (8K x 16) Flash |
| EEPROM Size | 512 B |
| SRAM Size | 1 KB |
| Maximum Clock Speed | 16 MHz |
| Throughput | Up to 16 MIPS at 16 MHz |
| Supply Voltage Range | 2.7 V to 5.5 V |
| Number of I/O Lines | 54 |
| General Purpose Working Registers | 32 |
| Instruction Set | 133 powerful instructions, most single clock cycle |
| ADC Resolution | 10-bit successive approximation |
| Package | 64-pin TQFP (14 x 14 mm, 1 mm height) |
| Mounting Type | Surface Mount |
| Operating Temperature | -40C to +85C (industrial) |
| Debug Interface | JTAG (boundary-scan and on-chip debug) |
| Communication Interfaces | SPI, UART/USART, USI |
| Brown-out Detection | Programmable |
| Watchdog Timer | Programmable on-chip |
| RoHS Status | Compliant |
ATMEGA165A-AU Pin Configuration
| Pin 1 | PB0 — Port B, bit 0 (also XCK/PCINT0) |
| Pin 2 | PB1 — Port B, bit 1 (also T1/PCINT1) |
| Pin 3 | PB2 — Port B, bit 2 (also INT2/PCINT2) |
| Pin 4 | PB3 — Port B, bit 3 (also OC0A/PCINT3) |
| Pin 5 | PB4 — Port B, bit 4 (also OC0B/PCINT4) |
| Pin 6 | PB5 — Port B, bit 5 (also OC1A/PCINT5) |
| Pin 7 | PB6 — Port B, bit 6 (also OC1B/PCINT6) |
| Pin 8 | PB7 — Port B, bit 7 (also OC2A/PCINT7) |
| Pin 9 | RESET — Reset input (active low) |
| Pin 10 | VCC — Digital supply voltage |
| Pin 11 | GND — Ground |
| Pin 12 | XTAL2 — Crystal oscillator output |
| Pin 13 | XTAL1 — Crystal oscillator input / external clock |
| Pin 14 | PD0 — Port D, bit 0 (also RXD/PCINT16) |
| Pin 15 | PD1 — Port D, bit 1 (also TXD/PCINT17) |
| Pin 16 | PD2 — Port D, bit 2 (also INT0/PCINT18) |
| Pin 17 | PD3 — Port D, bit 3 (also INT1/PCINT19) |
| Pin 18 | PD4 — Port D, bit 4 (also OC2B/PCINT20) |
| Pin 19 | PD5 — Port D, bit 5 (also PCINT21) |
| Pin 20 | PD6 — Port D, bit 6 (also PCINT22) |
| Pin 21 | PD7 — Port D, bit 7 (also PCINT23) |
| Pin 22 | PC0 — Port C, bit 0 (also ADC0/PCINT8) |
| Pin 23 | PC1 — Port C, bit 1 (also ADC1/PCINT9) |
| Pin 24 | PC2 — Port C, bit 2 (also ADC2/PCINT10) |
| Pin 25 | PC3 — Port C, bit 3 (also ADC3/PCINT11) |
| Pin 26 | PC4 — Port C, bit 4 (also ADC4/PCINT12) |
| Pin 27 | PC5 — Port C, bit 5 (also ADC5/PCINT13) |
| Pin 28 | PC6 — Port C, bit 6 (also ADC6/PCINT14) |
| Pin 29 | PC7 — Port C, bit 7 (also ADC7/PCINT15) |
| Pin 30 | AVCC — Analog supply voltage for ADC |
| Pin 31 | GND — Ground |
| Pin 32 | AREF — Analog reference voltage for ADC |
| Pin 33 | PA0 — Port A, bit 0 (also ADC8/PCINT24) |
| Pin 34 | PA1 — Port A, bit 1 (also ADC9/PCINT25) |
| Pin 35 | PA2 — Port A, bit 2 (also ADC10/PCINT26) |
| Pin 36 | PA3 — Port A, bit 3 (also ADC11/PCINT27) |
| Pin 37 | PA4 — Port A, bit 4 (also ADC12/PCINT28) |
| Pin 38 | PA5 — Port A, bit 5 (also ADC13/PCINT29) |
| Pin 39 | PA6 — Port A, bit 6 (also ADC14/PCINT30) |
| Pin 40 | PA7 — Port A, bit 7 (also ADC15/PCINT31) |
| Pin 41 | PG0 — Port G, bit 0 (also PCINT32) |
| Pin 42 | PG1 — Port G, bit 1 (also PCINT33) |
| Pin 43 | PG2 — Port G, bit 2 (also PCINT34) |
| Pin 44 | PG3 — Port G, bit 3 (also PCINT35) |
| Pin 45 | PG4 — Port G, bit 4 (also PCINT36) |
| Pin 46 | PG5 — Port G, bit 5 (also PCINT37) |
| Pin 47 | PE0 — Port E, bit 0 (also PCINT38) |
| Pin 48 | PE1 — Port E, bit 1 (also PCINT39) |
| Pin 49 | PE2 — Port E, bit 2 (also PCINT40) |
| Pin 50 | PE3 — Port E, bit 3 (also PCINT41) |
| Pin 51 | PE4 — Port E, bit 4 (also PCINT42) |
| Pin 52 | PE5 — Port E, bit 5 (also PCINT43) |
| Pin 53 | PE6 — Port E, bit 6 (also PCINT44) |
| Pin 54 | PE7 — Port E, bit 7 (also PCINT45) |
| Pin 55 | PF0 — Port F, bit 0 (also ADC16/PCINT46) |
| Pin 56 | PF1 — Port F, bit 1 (also ADC17/PCINT47) |
| Pin 57 | PF2 — Port F, bit 2 (also ADC18/PCINT48) |
| Pin 58 | PF3 — Port F, bit 3 (also ADC19/PCINT49) |
| Pin 59 | PF4 — Port F, bit 4 (also ADC20/PCINT50) |
| Pin 60 | PF5 — Port F, bit 5 (also ADC21/PCINT51) |
| Pin 61 | PF6 — Port F, bit 6 (also ADC22/PCINT52) |
| Pin 62 | PF7 — Port F, bit 7 (also ADC23/PCINT53) |
| Pin 63 | GND — Ground |
| Pin 64 | VCC — Digital supply voltage |
Typical Applications
ATMEGA165A-AU is suitable for 6 applications: Industrial Control Panels, Battery-Powered Portable Instruments, Home Automation Nodes, Motor Control, Legacy Embedded System Migration, Sensor Data Acquisition.
Industrial Control Panels
The ATMEGA165A-AU fits industrial control panels because its 54 general-purpose I/O lines and -40C to +85C operating range allow direct interfacing to relays, opto-isolated inputs, and motor drivers without external glue logic. Running at 16 MHz and 16 MIPS, it executes ladder-logic or state-machine firmware fast enough for scan cycles under 1 ms. The integrated programmable watchdog timer and brown-out detection keep the controller in a known state during supply dips, a common condition on factory 24 V rails. A typical implementation uses Port A and Port C for digital I/O, the 10-bit ADC for 4-20 mA loop sensing, and the USART for Modbus RTU communication. The trade-off versus a 32-bit ARM Cortex-M0 is lower throughput and smaller RAM, but the 5 V-tolerant I/O and simple architecture reduce BOM cost and firmware complexity in legacy panel upgrades.
Recommended
Battery-Powered Portable Instruments
The ATMEGA165A-AU suits battery-powered instruments because it operates from 2.7 V to 5.5 V, allowing direct connection to a 3.6 V lithium-thionyl-chloride cell or a 3.3 V regulated rail without an extra boost stage. Multiple sleep modes and fully static operation let firmware halt the clock between measurements, and the 512 B EEPROM stores calibration coefficients without an external memory device. In a handheld data logger, the 10-bit ADC samples a sensor bridge while the USART streams results to a wireless module. The main trade-off is that the A version draws more active current than the picoPower ATMEGA165PA-AU, so designs targeting multi-year battery life should evaluate the PA variant. For instruments with rechargeable batteries and frequent use, the ATMEGA165A-AU remains a cost-effective choice.
Recommended
Home Automation Nodes
The ATMEGA165A-AU works well in home automation nodes because its 54 I/O lines can drive multiple relays, read wall-switch inputs, and interface to a wireless transceiver simultaneously, all from a single 64-pin TQFP. The 16 KB Flash holds a communication stack plus application logic, while the 1 KB SRAM buffers incoming frames. A typical node uses the SPI port for an RF module, the USART for a wired bus, and the ADC for a light or temperature sensor. Because the device runs from 2.7 V to 5.5 V, it can share a 5 V rail with relays and a 3.3 V rail with the radio through simple decoupling. The trade-off versus a dedicated wireless SoC is higher component count, but the ATMEGA165A-AU offers deterministic timing and full control over protocol implementation.
Recommended
Motor Control
The ATMEGA165A-AU supports motor control applications because its 16 MIPS throughput at 16 MHz provides enough computational headroom for PID loops and commutation timing, while the 10-bit ADC samples current-sense shunts and potentiometers. Three flexible timer/counters generate PWM waveforms for H-bridge or three-phase inverter drive, and the programmable watchdog timer recovers the controller if firmware locks up during a fault. In a brushed-DC pump controller, the device reads a pressure sensor on the ADC, drives a MOSFET gate through a timer PWM channel, and reports status over the USART. The trade-off compared with a dedicated motor-control MCU is the absence of hardware dead-time insertion and advanced PWM modes, so three-phase designs need careful software timing or an external gate driver with built-in dead time.
Recommended
Legacy Embedded System Migration
The ATMEGA165A-AU is a practical migration target for legacy embedded systems because it retains the classic AVR instruction set, 5 V operation, and through-hole-friendly development flow that older ATmega designs rely on. Teams moving from discontinued 8-bit parts can port assembly or C firmware with minimal changes, since the 133-instruction set and 32 working registers are unchanged across AVR generations. The 64-pin TQFP footprint matches the ATmega165/325/645 family, so an existing PCB can often accept the device with only a BOM update. The trade-off is that newer designs may prefer the picoPower ATMEGA165PA-AU or a 32-bit device for more RAM and peripherals. For sustaining long-lifecycle industrial products, the ATMEGA165A-AU offers a stable, well-documented migration path.
Recommended
Sensor Data Acquisition
The ATMEGA165A-AU is effective in sensor data acquisition because its 10-bit successive-approximation ADC, 54 I/O lines, and 1 KB SRAM allow multi-channel sampling with local buffering before transmission. In a temperature and pressure monitoring unit, the ADC scans thermistor dividers and bridge outputs while the USART or SPI forwards averaged readings to a host controller. The 512 B EEPROM stores sensor calibration constants, eliminating trim potentiometers and improving long-term accuracy. Running at 16 MHz, the device completes a full multi-channel scan in well under a millisecond, fast enough for most industrial monitoring loops. The trade-off versus a dedicated 12-bit or 16-bit ADC plus a smaller MCU is lower resolution, so designs requiring high precision should add an external converter on the SPI bus.
Recommended
Recommended Products Summary
Engineering reference data for ATMEGA165A-AU — comparison, design guidance, and compliance information.
Selection Guide
Comparison with Alternatives
| Parameter | This Product | ATMEGA165PA-AU | ATMEGA165A-AUR | ATMEGA325A-AU | ATMEGA645A-AU | ATMEGA169A-AUR |
|---|---|---|---|---|---|---|
| Package | 64-pin TQFP (14x14) | 64-pin TQFP (14x14) - same | 64-pin TQFP (14x14) - same | 64-pin TQFP (14x14) - same | 64-pin TQFP (14x14) - same | 64-pin TQFP (14x14) - same |
| Brand | Microchip Technology | Microchip Technology | Microchip Technology | Microchip Technology | Microchip Technology | Microchip Technology |
| Flash Memory | 16 KB | 16 KB | 16 KB | 32 KB | 64 KB | 16 KB |
| SRAM | 1 KB | 1 KB | 1 KB | 2 KB | 4 KB | 1 KB |
| EEPROM | 512 B | 512 B | 512 B | 1 KB | 2 KB | 512 B |
| Maximum Clock Speed | 16 MHz | 16 MHz | 16 MHz | 16 MHz | 16 MHz | 16 MHz |
| Supply Voltage | 2.7 V to 5.5 V | 2.7 V to 5.5 V | 2.7 V to 5.5 V | 2.7 V to 5.5 V | 2.7 V to 5.5 V | 2.7 V to 5.5 V |
| I/O Lines | 54 | 54 | 54 | 54 | 54 | 54 |
| LCD Controller | No | No | No | No | No | Yes (4x25 segments) |
| Low-Power Technology | Standard | picoPower | Standard | Standard | Standard | picoPower |
Key Differentiators
- Standard-power AVR with full 54 I/O in 64-pin TQFP (vs ATMEGA165PA-AU)
- Tray packaging for prototype and low-volume builds (vs ATMEGA165A-AUR)
- Lower cost than larger-Flash family members (vs ATMEGA645A-AU)
- No LCD controller overhead for non-display designs (vs ATMEGA169A-AUR)
Design Notes
Decouple every VCC pin (pins 10 and 64) with a 100 nF ceramic capacitor placed within a few millimeters of the pin, and add a 10 uF bulk capacitor near the package. The AVCC pin (pin 30) requires its own 100 nF decoupling plus a series ferrite bead or inductor when the ADC is used, to isolate digital switching noise from the analog supply. AREF (pin 32) should be bypassed with 100 nF to GND. Estimated: at 16 MHz and 5 V, core current is on the order of 10-15 mA, so a 10 uF bulk capacitor provides ample transient reserve for typical load steps.
Route the crystal between XTAL1 (pin 13) and XTAL2 (pin 12) with the shortest possible traces, keeping the load capacitors grounded to a local analog ground island. Do not route high-speed digital signals under the crystal or its load capacitors. The JTAG pins (TCK, TMS, TDI, TDO) share Port F, so reserve a 10-pin debug header footprint and keep those traces short and free of stubs to preserve signal integrity during in-circuit programming and boundary-scan testing.
The RESET pin (pin 9) is active low and must not be left floating; add an external 10 kOhm pull-up to VCC and a 100 nF capacitor to GND for reliable power-on reset, especially in noisy industrial environments. Ensure the brown-out detection level is programmed to match the supply rail, otherwise the device may execute code below the minimum 2.7 V and corrupt EEPROM writes. When migrating firmware from an ATmega164/324/644 device, re-verify fuse settings and pin mapping because Port G and Port F assignments differ between the 44-pin and 64-pin families.
Compliance Information
DigiKey lists the ATMEGA165A-AU as RoHS compliant and lead-free. REACH, halogen-free, and conflict-minerals status were not stated in the retrieved data and are marked unknown rather than assumed. The device is not AEC-Q100 qualified; automotive designs should use an automotive-grade AVR variant.